An Oceanic Small-UAS with Near–Surface Soaring Flight Sensory Design and Onboard Deep-Learned Meteorological Perception
International Conference on Unmanned Aircraft Systems (ICUAS), 2026
PhD Candidate, CSE
University of Nevada, Reno
Developing autonomous systems capable of overcoming mobility and manipulation constraints
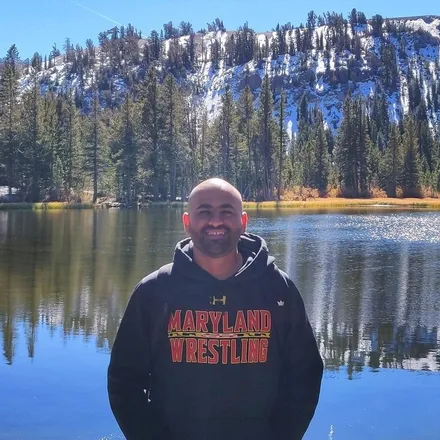
I am a PhD candidate in the Robotic Workers Lab at the University of Nevada, Reno, advised by Prof. Christos Papachristos. My research focuses on developing resilient autonomous robotic systems that can overcome mobility and manipulation constraints.
Before my PhD, I completed my Masters in Robotics at the University of Maryland, College Park, where I was a member of the Perception and Robotics Group (PRG) advised by Prof. Yiannis Aloimonos and worked on autonomous vision-based navigation for quadrotors. Earlier, I was a Research Associate at IIIT-Delhi with Dr. P.B. Sujit and Dr. Sanjit Kaul on a self-driving car project for Indian urban scenarios.
In my spare time, I fly my own custom-built FPV drone and go on hikes.
Ph.D. Candidate, Computer Science & Engineering
Robotic Workers Lab · University of Nevada, Reno
| Developing resilient autonomous robotic systems capable of overcoming mobility and manipulation constraints
Masters in Robotics
Perception & Robotics Group · University of Maryland, College Park
| Autonomous vision-based navigation for nano quadrotors
Research Associate
IIIT-Delhi
| Self-driving cars in Indian urban traffic
B.Tech, Electrical Engineering
Bharati Vidyapeeth's College of Engineering, GGSIPU
| Hexapod locomotion using inverse kinematics
International Conference on Unmanned Aircraft Systems (ICUAS), 2026
AIAA SciTech Forum, 2025
ICRA 2025IEEE International Conference on Robotics and Automation (ICRA), 2025
International Conference on Unmanned Aircraft Systems (ICUAS), 2024
IEEE Aerospace Conference, 2023
International Conference on Unmanned Aircraft Systems (ICUAS), 2023
International Conference on Unmanned Aircraft Systems (ICUAS), 2023
ICRA 2023IEEE International Conference on Robotics and Automation (ICRA), 2023
ICRA 2022IEEE International Conference on Robotics and Automation (ICRA), 2022
International Conference on Unmanned Aircraft Systems (ICUAS), 2022
International Conference on Unmanned Aircraft Systems (ICUAS), 2022
IEEE Aerospace Conference, 2021
IROS 2021IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2021Best paper finalist in two categories
ICRA 2021IEEE International Conference on Robotics and Automation (ICRA), 2021
International Symposium on Visual Computing (ISVC), 2020
International Journal of Control Theory and Applications, vol. 9, no. 41, 2016
IEEE India Conference (INDICON), 2015
Estimation of IMU orientation using an Unscented Kalman Filter.
End-to-end pipeline to swap faces in a video, just like Snapchat's face swap filter.
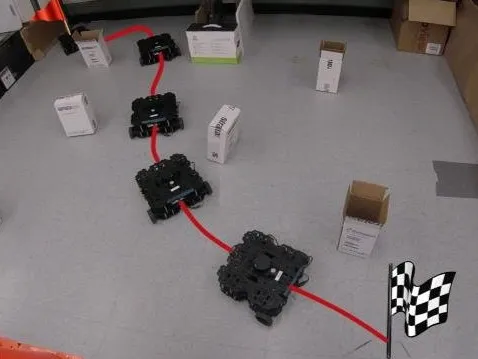
A* path planning with differential constraints on a TurtleBot in Gazebo.
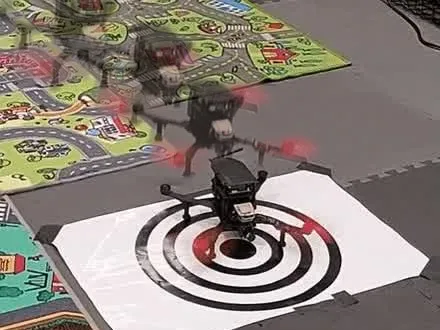
Estimated the 3D pose of a CCTag marker in real time to land a quadrotor on it.
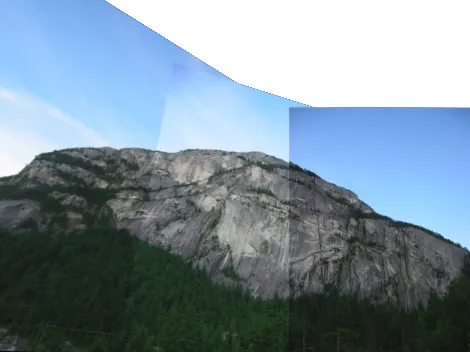
Panorama stitching using deep-learning and traditional approaches.
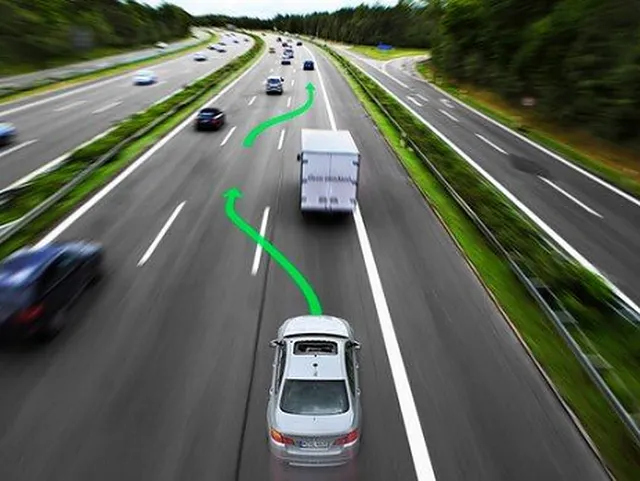
Implemented A* to find a path from start to goal in a static map.
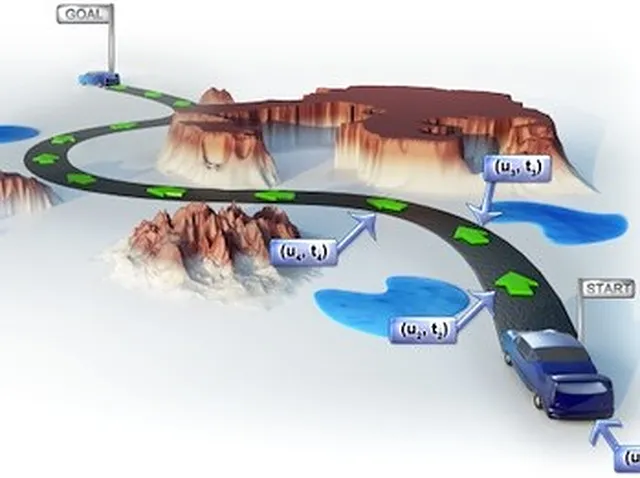
Implemented Dijkstra's algorithm to find a path from start to goal in a static map.
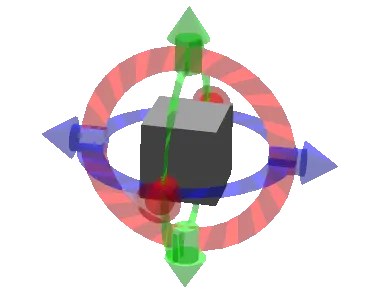
Estimation of IMU orientation using a Madgwick filter.
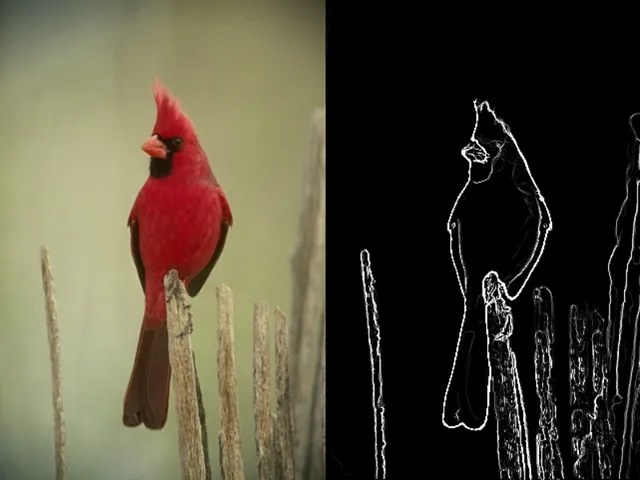
Boundary detection using a modified Probability of Boundary method.
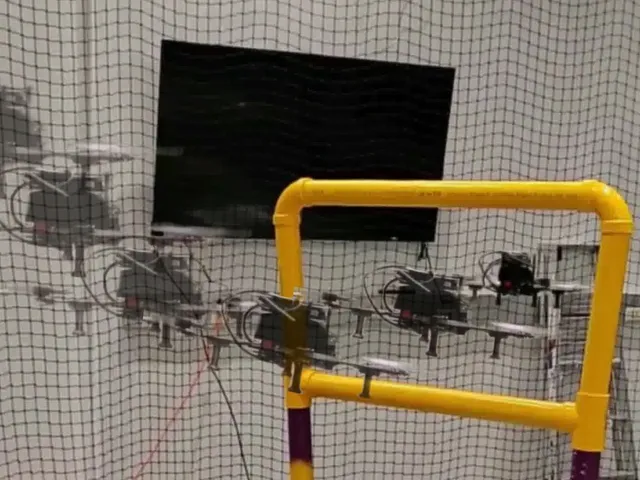
Gaussian Mixture Model to detect coloured windows, used as feedback to autonomously fly a drone through them.
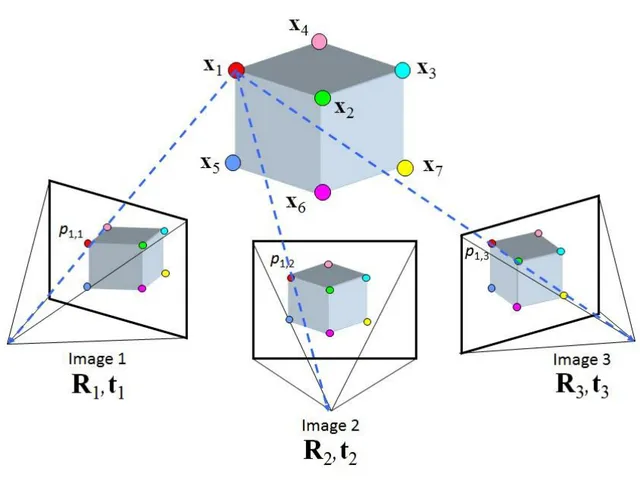
Reconstructed a 3D scene and recovered the camera poses from multiple images.
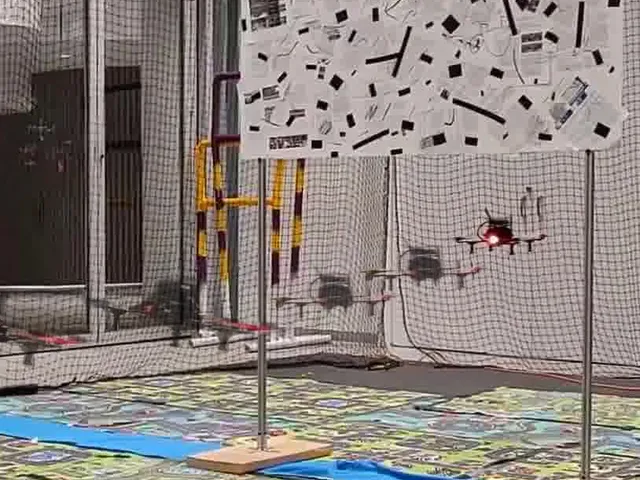
Detected a wall in real time with a monocular camera on a quadrotor, then avoided it.
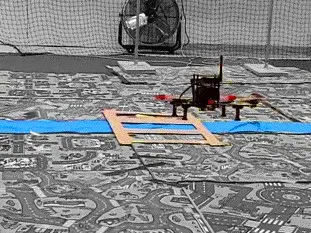
Detected a bridge across a river and navigated a quadrotor to the other side by flying over it.
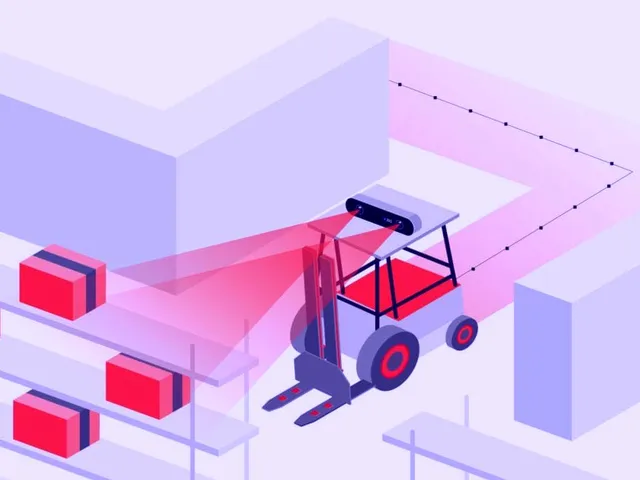
Estimated the 3D trajectory of a stereo-camera quadrotor using the optical flow equation.
Implemented and evaluated different CNN architectures for image classification.
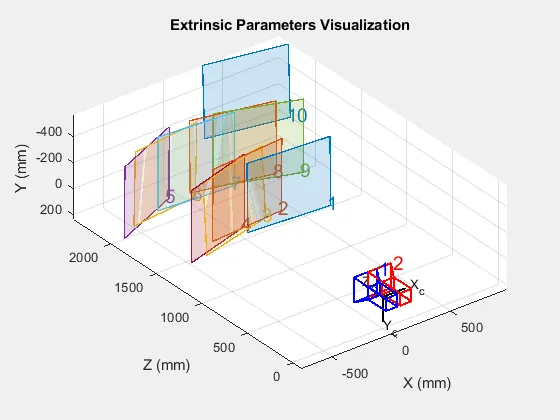
Estimated intrinsic camera parameters — focal length, distortion coefficients and principal point.
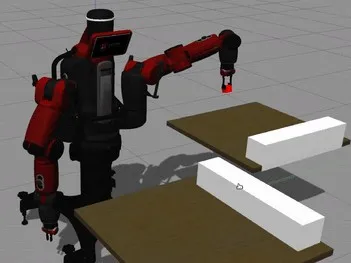
Simple pick and place using Baxter's ROS API with its built-in kinematics and inverse-kinematics engine.
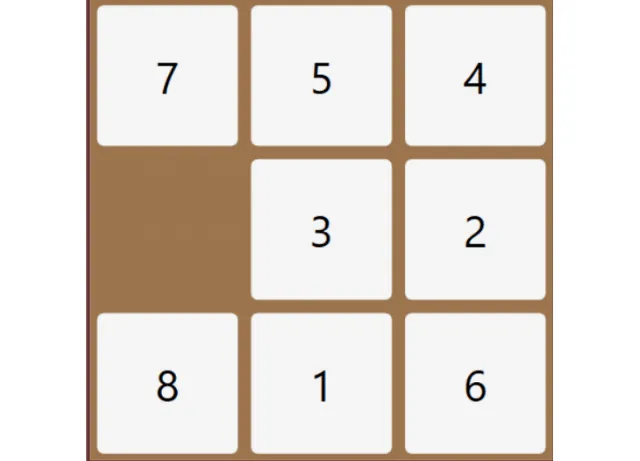
Solved the 8-piece puzzle with brute-force search to reach a goal tile configuration.